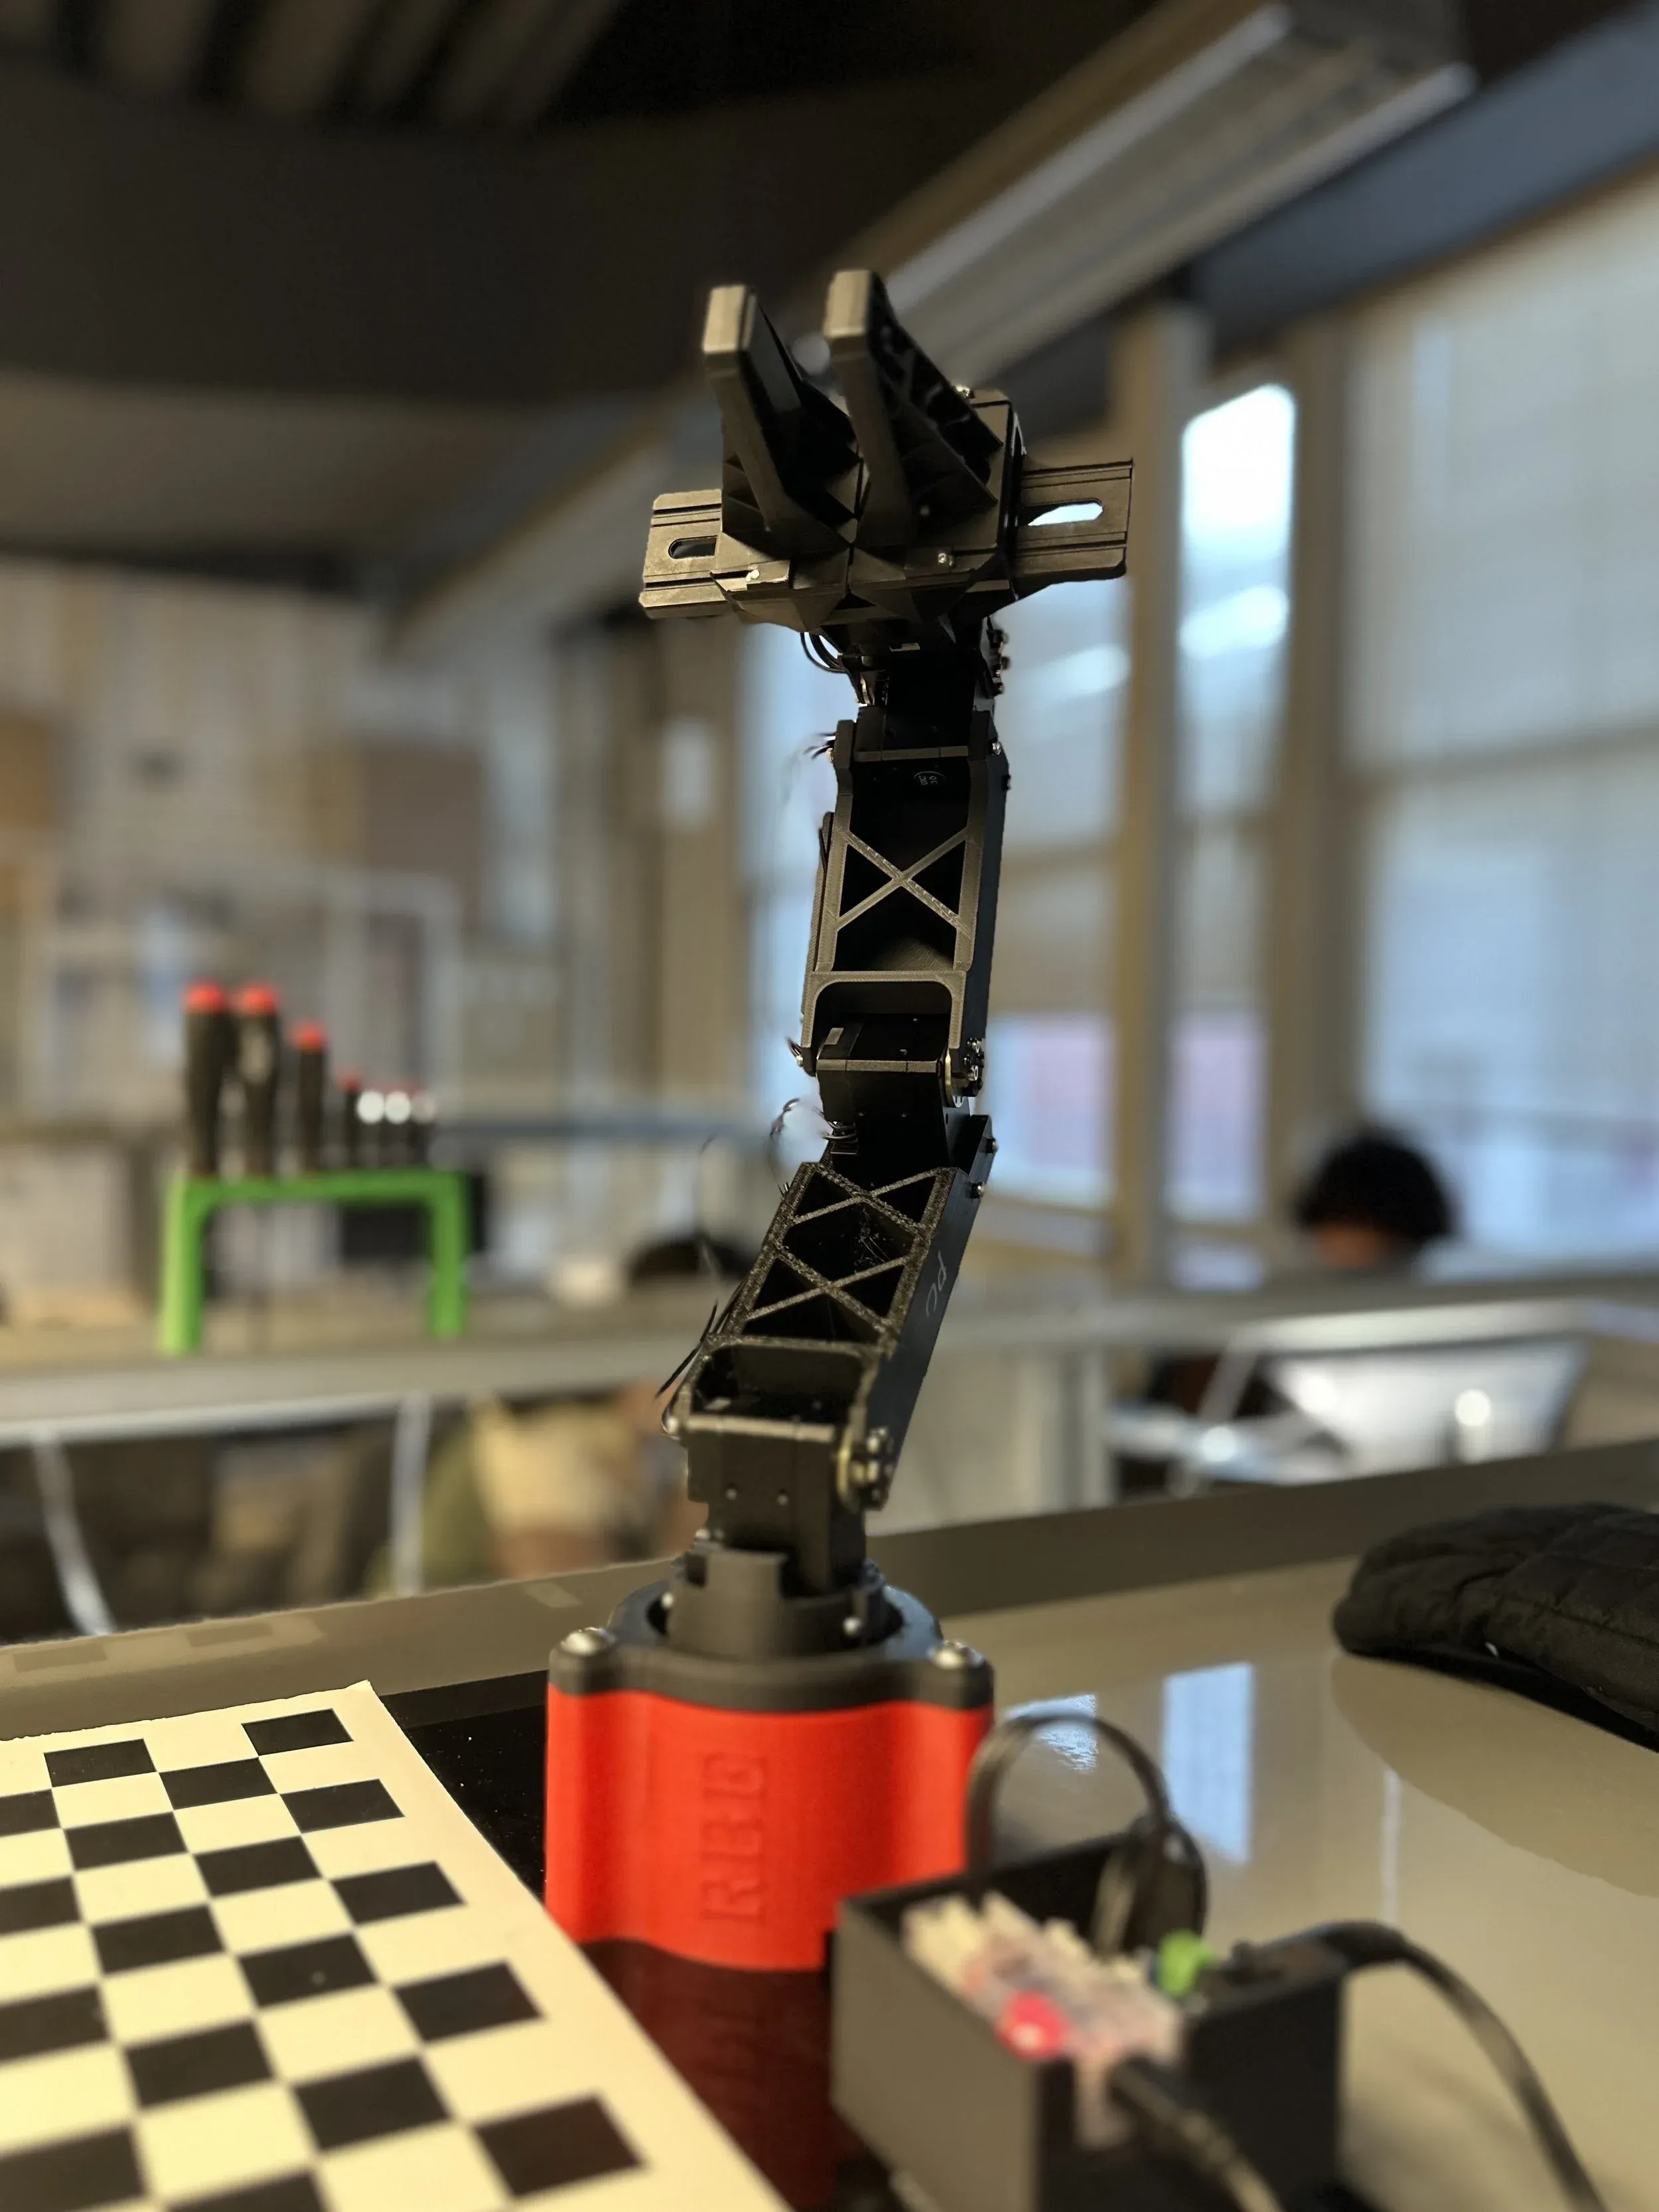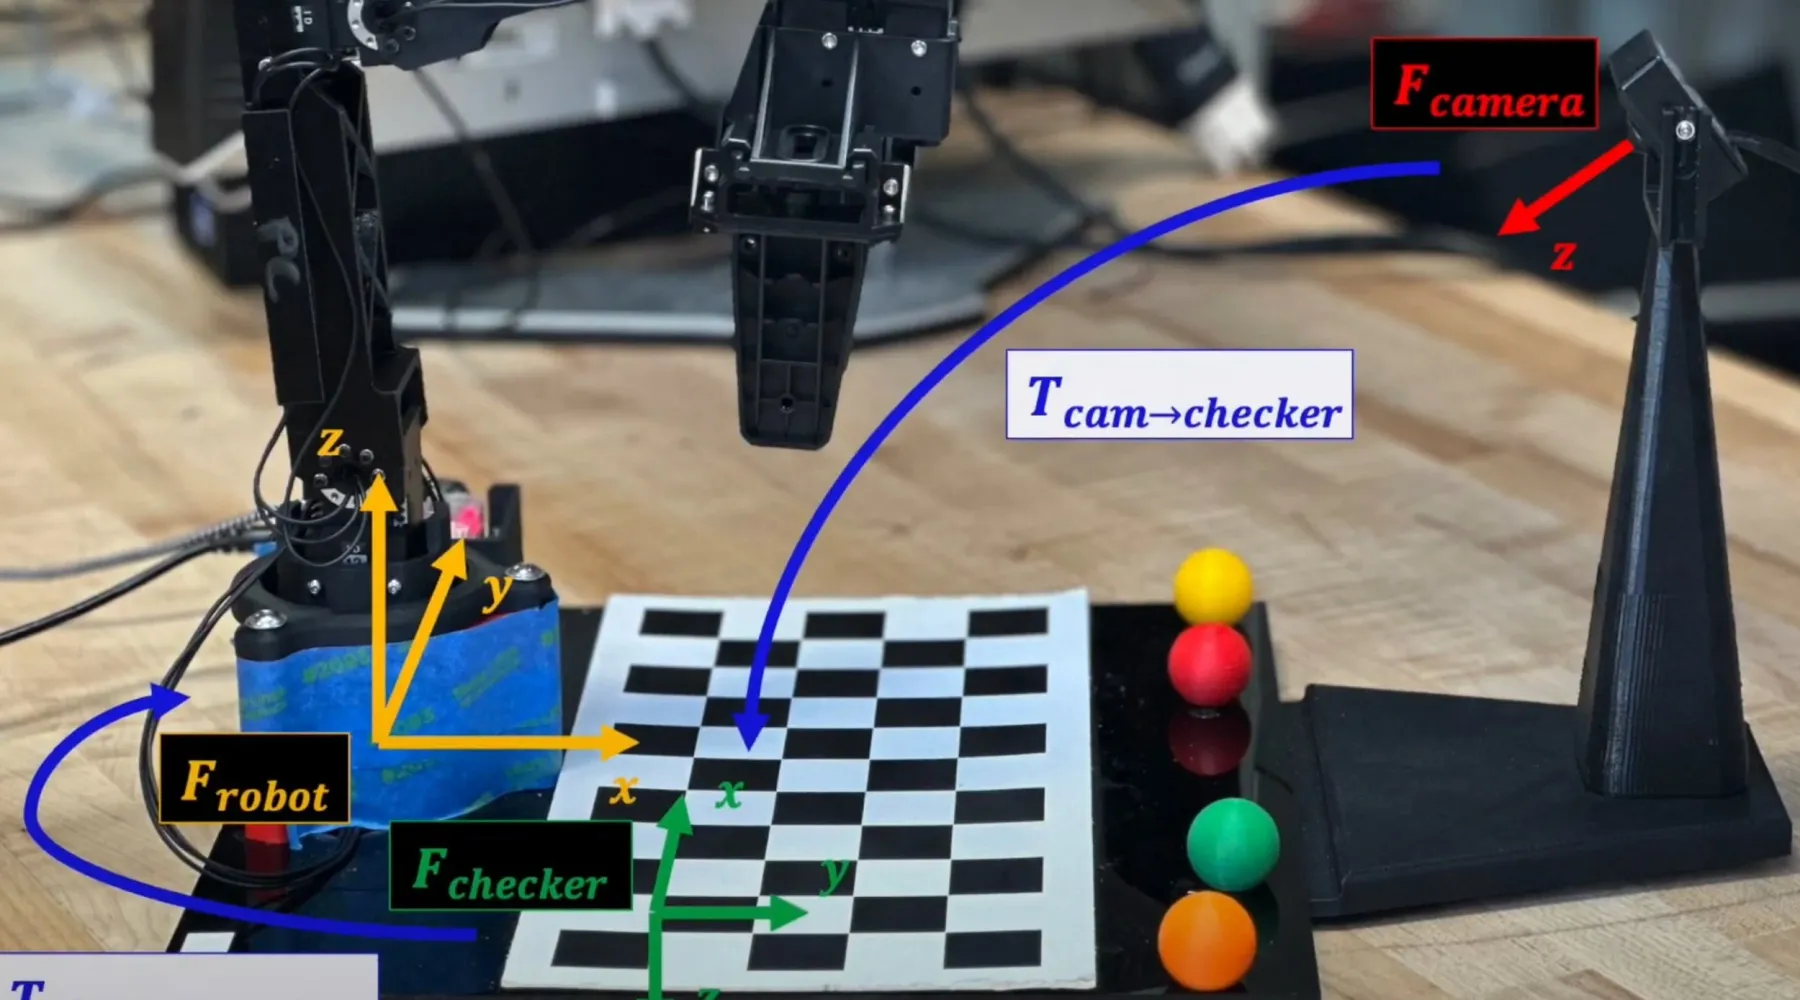
Overview Video of Our Robot
Source code: the team repository (RBE3001-C24/RBE3001_C24_Team08) is private under WPI’s course organization; the full report below covers the design and results.
Kinematic Modeling:
- DH convention (Denavit-Hartenberg)
- POE (Product Of Exponentials)
Programming Language: MATLAB
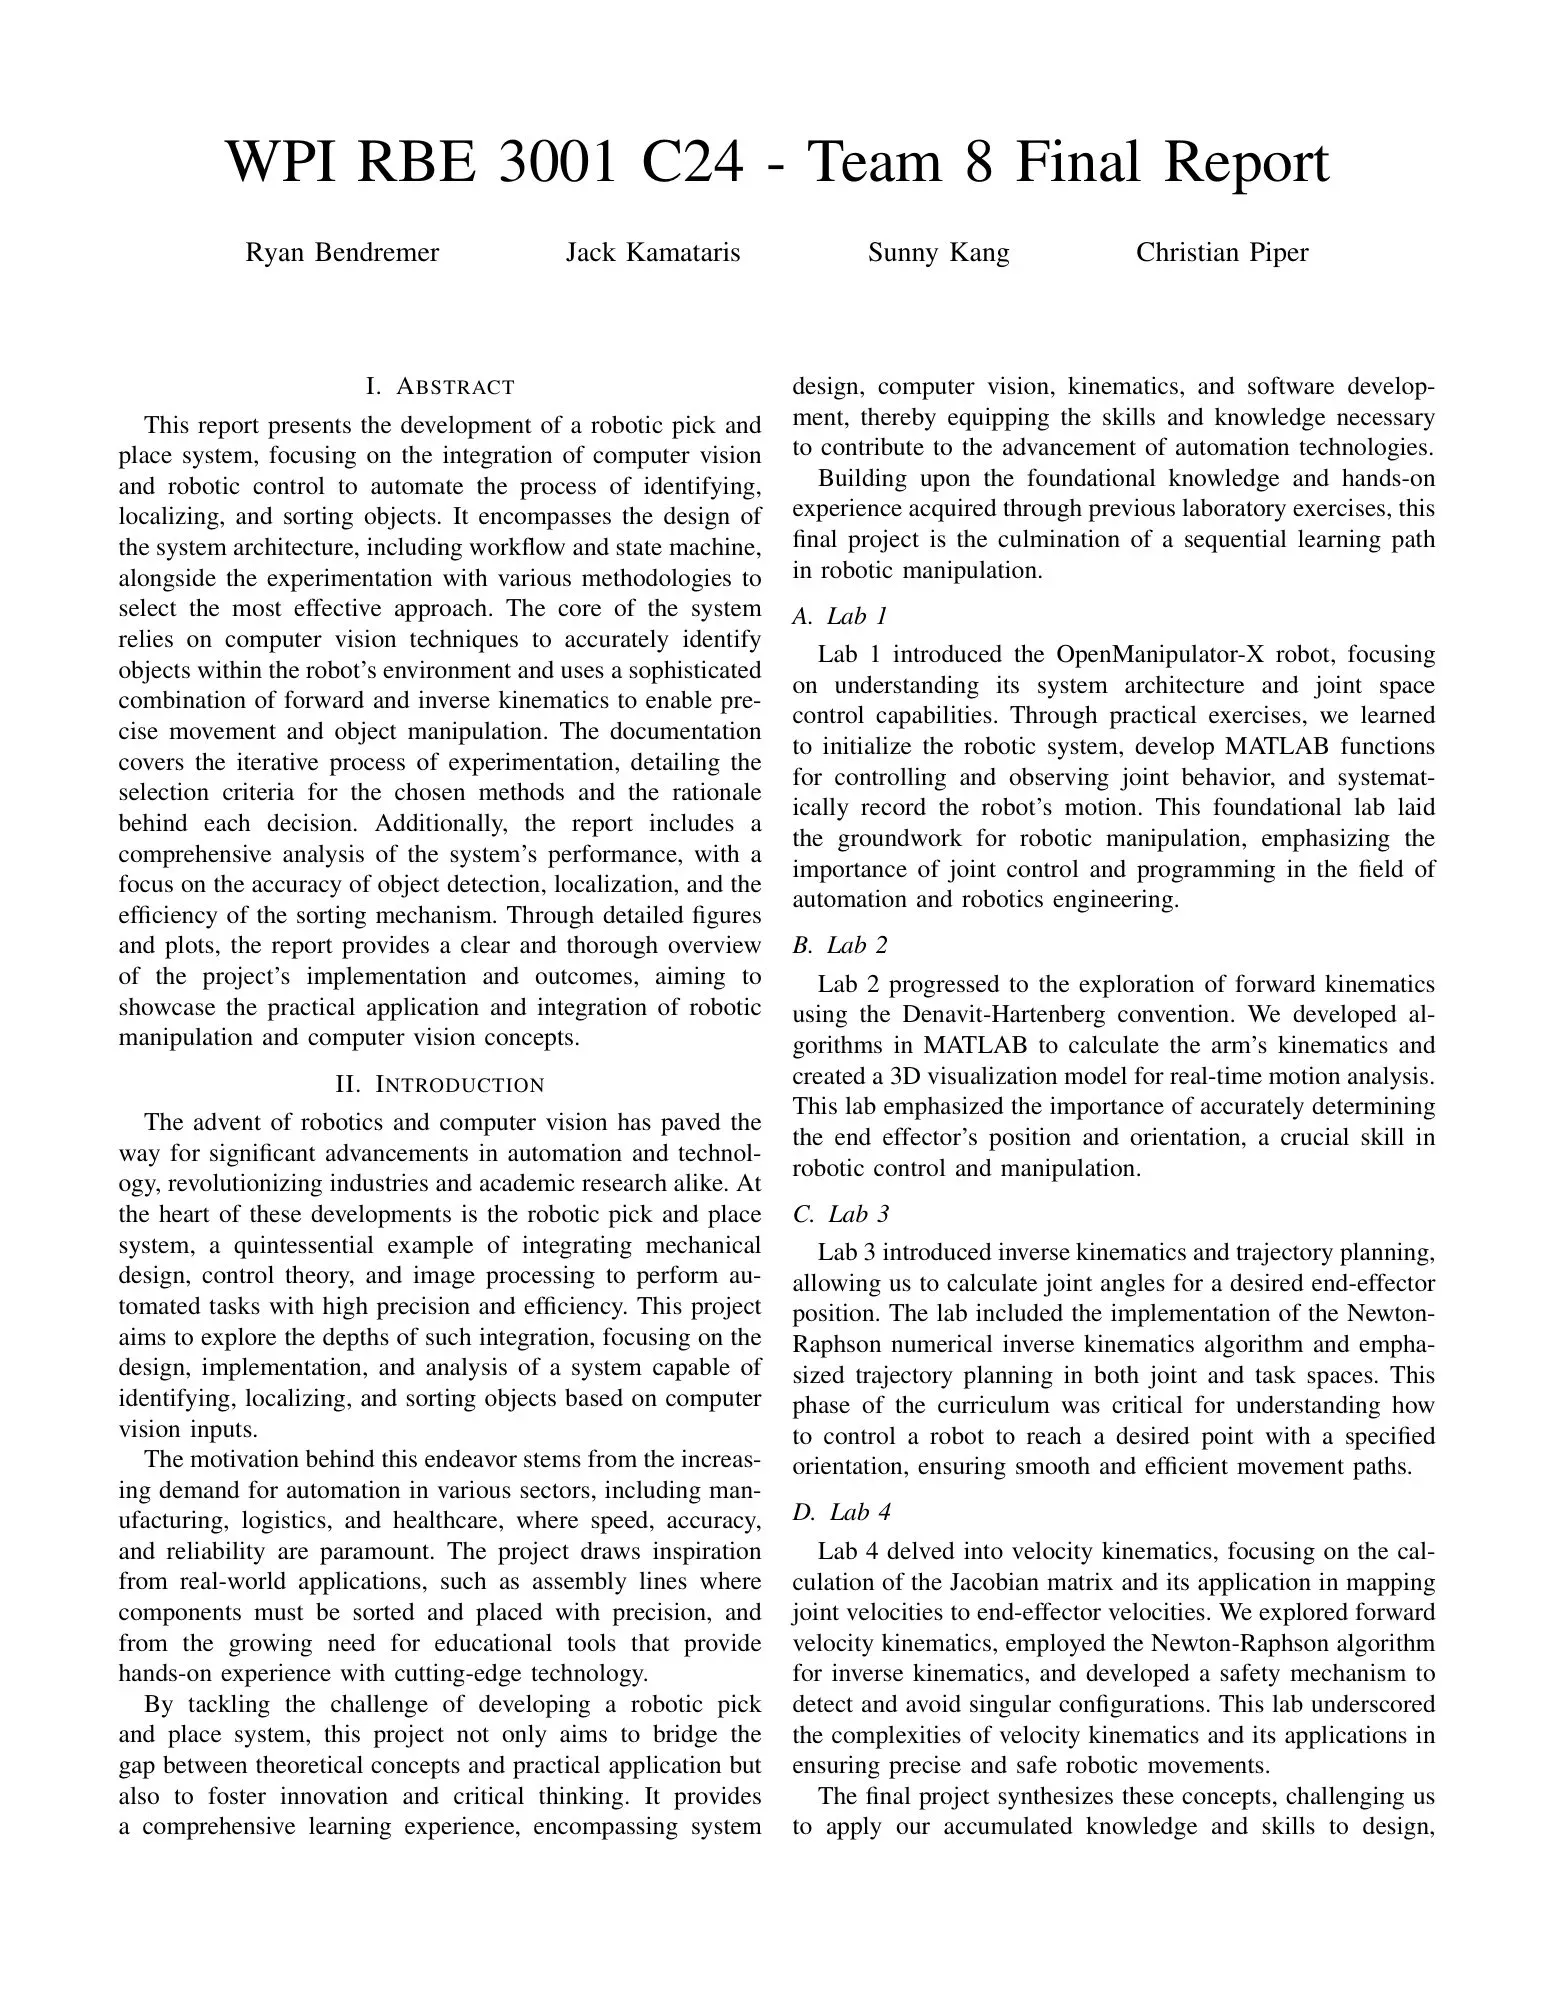
Check Out My Team's Final Report!